
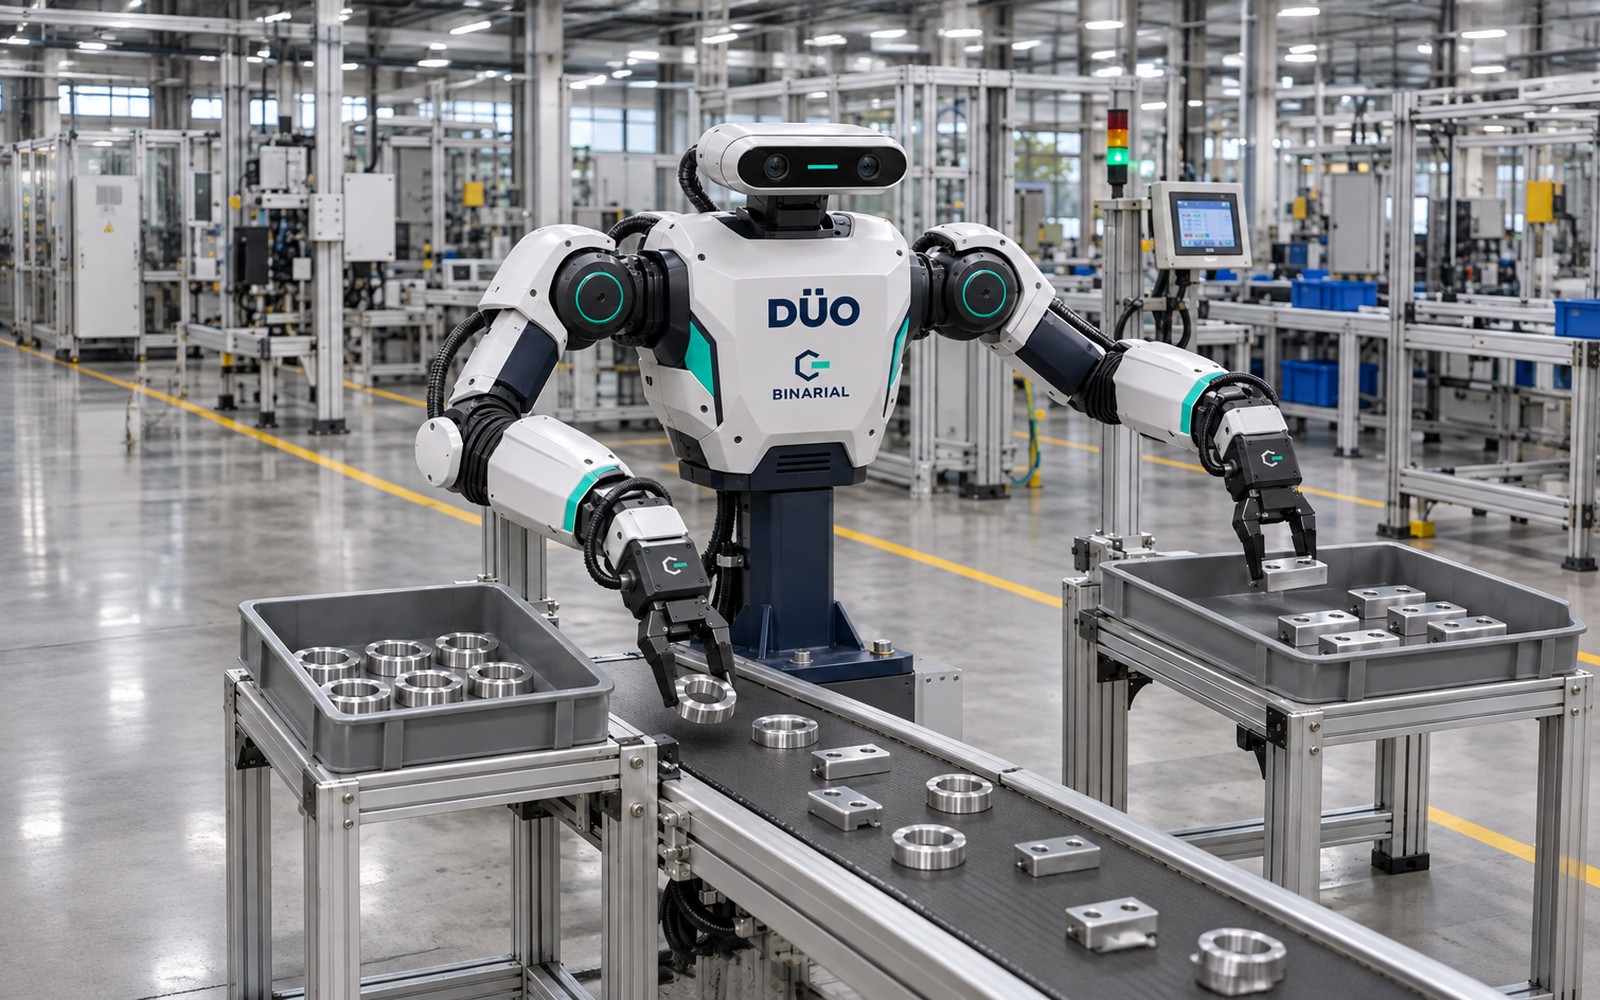
Two-arm torso for industrial and research manipulation.
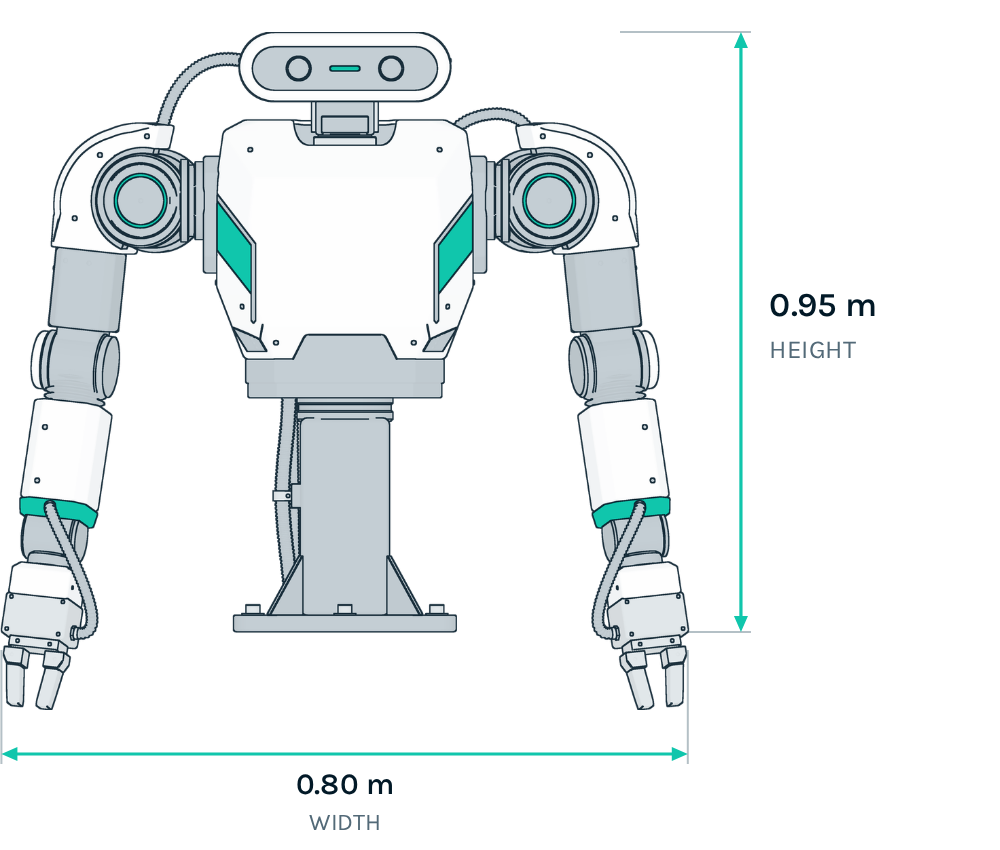
0.95 m height0.80 m width
Capabilities

Coordinated manipulation
Individual and coordinated control of both arms.

Teleoperation
Control and supervision of the task.

Demonstrations
Recording of demonstrations for reusable task capabilities.
From object to work cycle

01 Object and grip
Definition of the objects, the tools and the gripping points.

02 Workstation and setup
Configuration of the torso, the working positions and perception.

03 Task and control
Sequence, supervision, cycle and expected result of the application.
The task and the environment define the routes, tools, observation, communications and supervision of each configuration.
Features
- Manipulation
Individual and coordinated control
- Operation
Teleoperation and supervision
- Learning
Recording of demonstrations
- Mobility
No locomotion of its own
- Equipment
Tools, mounting and perception depending on the task
- Height
0.95 m
- Width
0.80 m